DnnOnnxDetector C++ library
v1.0.1
Table of contents
- Overview
- Versions
- Library files
- Key features and capabilities
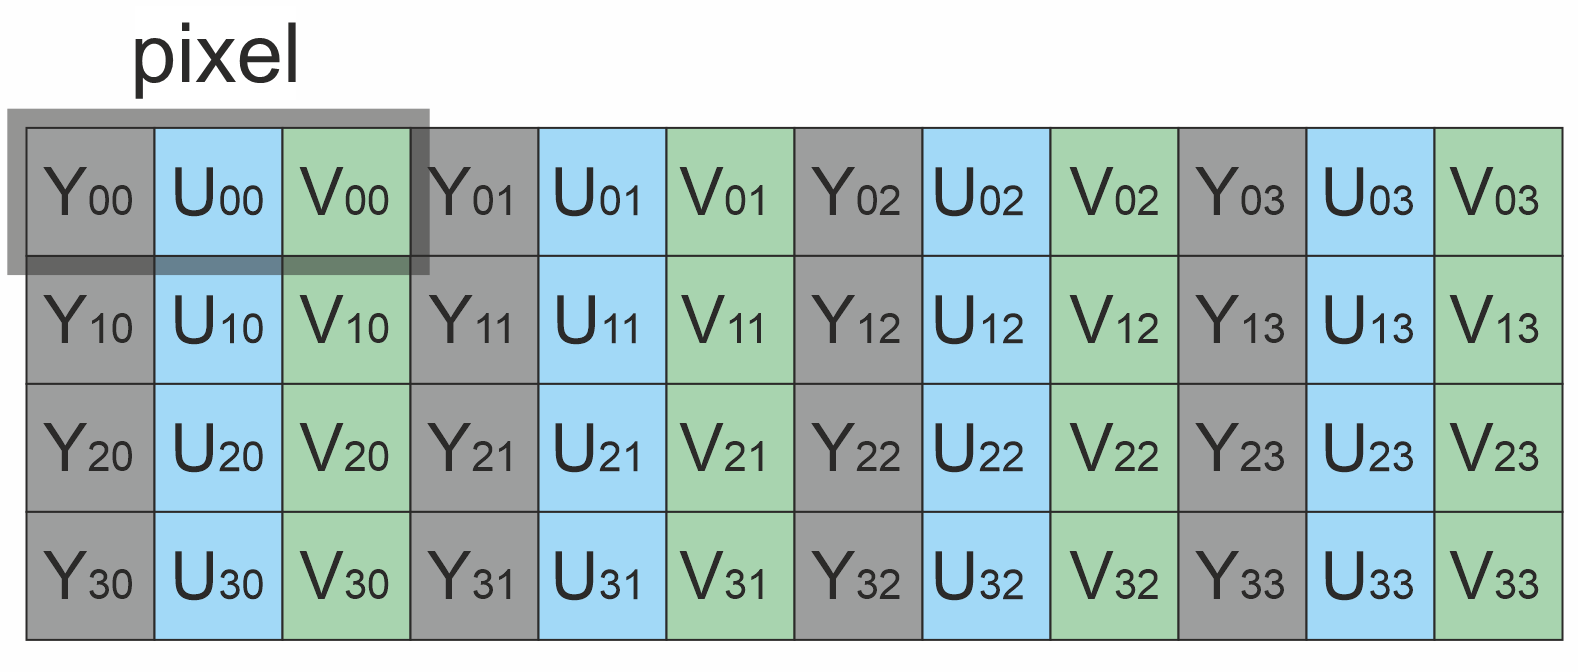
- Supported pixel formats
- Library principles
- DnnOnnxDetector class description
- DnnOnnxDetector class declaration
- getVersion method
- initObjectDetector method
- setParam method
- getParam method
- getParams method
- getObjects method
- executeCommand method
- detect method
- setMask method
- decodeAndExecuteCommand method
- encodeSetParamCommand method of ObjectDetector class
- encodeCommand method of ObjectDetector class
- decodeCommand method of ObjectDetector class
- Data structures
- ObjectDetectorParams class description
- Build and connect to your project
- OpenVINO execution provider
- Portability
- Example
- Benchmark
- Demo application
Overview
The DnnOnnxDetector C++ library performs automatic detection of objects in videos through the utilization of neural networks. The library is implemented in the C++17 standard and uses ONNX Runtime. It is tested with the Ultralytics YOLOv8 neural network model. The library configures the ONNX Runtime session, performs frame preprocessing (pixel format conversion and scaling), passes the frame to ONNX Runtime for computation and interprets the results. The network runs on the CPU by default, or on an Intel CPU or GPU with the OpenVINO execution provider of ONNX Runtime (see section OpenVINO execution provider). The library inherits the interface from the ObjectDetector class (provides an interface for object detectors). The library depends on the ImageResizer library for scaling and the FormatConverter library for pixel format conversion. The demo application depends on the SimpleFileDialog library (provides a function to open a video file via file dialog), the SimpleUI library (provides UI and drawing functions), the VSourceFile library (provides a video file reading function) and the VideoRecorderMp4 library (provides a video file recording function). The benchmark application depends on the VSourceFile library (provides a video file reading function). The example application depends on the VSourceFile library (provides a video file reading function) and the SimpleUI library (provides UI and drawing functions).
DnnOnnxDetector is general-purpose software: it is not tied to any sector or application, and the developer of a program decides what the program does with it.
Quick start: to build and run the demo application, the example and the benchmark step by step on Windows or Linux, see GETTING_STARTED.md.
Versions
Table 1 - Library versions.
| Version | Release date | What’s new |
|---|---|---|
| 1.0.0 | 20.10.2026 | First version. |
| 1.0.1 | 30.10.2026 | - Namespace rapidpixel for all classes. - The telemetry of ONNX Runtime is switched off before the first model is loaded. - The OpenVINO plugin library is registered once per process: several detectors in one process can use the OpenVINO execution provider. - The detection mask is checked before the library copies it. - Demo application without global objects. - Documentation updated. |
Library files
The library is supplied as source code only. The user is provided with a set of files in the form of a CMake project (repository). The repository structure is shown below:
CMakeLists.txt ----------------------- Main CMake file of the library.
src ---------------------------------- Folder with library source code.
    CMakeLists.txt ------------------- CMake file of the library.
    DnnOnnxDetector.cpp -------------- C++ class definition file.
    DnnOnnxDetector.h ---------------- Main library header file.
    DnnOnnxDetectorVersion.h --------- Header file with library version.
    DnnOnnxDetectorVersion.h.in ------ Service CMake file to generate version header.
    impl ----------------------------- Folder with implementation classes.
        BoxTracker.h ----------------- Header file of BoxTracker class.
        BoxTracker.cpp --------------- C++ implementation file of BoxTracker class.
        DnnOnnxDetectorImpl.h -------- Implementation header file.
        DnnOnnxDetectorImpl.cpp ------ C++ implementation file.
demo --------------------------------- Folder for demo application.
    CMakeLists.txt ------------------- CMake file for demo application.
    README.md ------------------------ Description of the demo application.
    main.cpp ------------------------- Source C++ file of demo application.
example ------------------------------ Folder for example application.
    CMakeLists.txt ------------------- CMake file of example application.
    main.cpp ------------------------- Source C++ file of example application.
benchmark ---------------------------- Folder with benchmark.
    CMakeLists.txt ------------------- CMake file of benchmark.
    main.cpp ------------------------- Source C++ file of benchmark.
static ------------------------------- Folder with images for the documentation, an example neural network model and a test video.
    thermal.onnx --------------------- Example of YOLOv8 neural network for thermal video (input size 640 x 640).
    test.mp4 ------------------------- Thermal test video (1280 x 720, 30 FPS, about 1 min 40 s).
The example model static/thermal.onnx was trained and exported with the Ultralytics package (YOLOv8): it is licensed under AGPL-3.0 by Ultralytics (the license is written in the metadata of the model), unless you have an Ultralytics Enterprise License.
Key features and capabilities
Table 2 - Key features and capabilities.
| Parameter and feature | Description |
|---|---|
| Programming language | C++ (standard C++17) using the ONNX Runtime library: version 1.23 or newer is required to build the library (it uses the execution provider device functions of ONNX Runtime 1.23 for all values of TYPE), tested with version 1.31.0. |
| Supported OS | Compatible with any operating system that supports the C++ compiler (C++17 standard) and the ONNX Runtime library. The OpenVINO execution provider (TYPE 1, 2 and 3) works on Windows and Linux only: the library looks for the plugin library in the folder of the executable file, which it gets from Windows or from /proc/self/exe on Linux. Tested on Windows 11 x64 and Linux x64 (Ubuntu 24.04 in WSL2), see section Portability. |
| Shape of detected objects | The library is capable of detecting objects of various shapes. The minimum and maximum height and width of the objects to be detected are set by the user in the library parameters. |
| Supported pixel formats | RGB24, BGR24 and YUV24. The library uses the RGB24 format for video processing. If the pixel format of the image is different from RGB24, the library pre-converts the pixel formats to RGB24. |
| Maximum and minimum video frame size | The minimum size of video frames to be processed is 32x32 pixels, and the maximum size is 8192x8192 pixels. The size of the video frames to be processed doesn’t have a significant impact on the computational speed, because input images are resized to input network size (usually 640x640 pixels). |
| Coordinate system | The algorithm uses a window coordinate system with the zero point in the upper left corner of the video frame. |
| Calculation speed | The processing time per video frame depends mostly on loaded neural network model and also on the computing platform used. The processing time per video frame can be estimated with the demo application. |
| Type of algorithm for detection of objects | To detect different objects on current frame, an interface for obtaining neural network model was implemented. This interface relies on ONNX Runtime implementation and utilizes its features such as: reading and launching neural network model and obtaining output results. Output data is cleaned up from overlapping boxes and correct types are assigned to output vector of objects. |
| Discreteness of computation of coordinates | The library utilizes the object bounding box for each detected object. If boxes of the same object type overlap (intersection over union greater than 0.4), only the box with the highest probability is kept. Boxes of different object types are never suppressed. This means the discreteness of library is strongly dependent on the loaded neural network model. |
| Working conditions | The library is designed to function on a variety of devices. Hardware acceleration is provided by the execution providers of ONNX Runtime. Supported devices: x86-64 or AArch64 CPU (TYPE 0, the CPU execution provider of ONNX Runtime without OpenVINO), Intel CPU with OpenVINO (TYPE 1), Intel integrated and discrete GPU with OpenVINO (TYPE 2 and 3, for example Intel UHD Graphics and Intel Arc), see section OpenVINO execution provider. The detector processes each frame independently, so camera movement does not impact the results. |
Supported pixel formats
Frame library (a dependency of DnnOnnxDetector library) contains Fourcc enum, which defines supported pixel formats (Frame.h file). DnnOnnxDetector library supports BGR24, RGB24 and YUV24 input pixel formats. The library uses the RGB24 format for video processing. If the pixel format of the image is different from RGB24, the library pre-converts the pixel formats to RGB24. A frame in any other pixel format is skipped (see detect method). Fourcc enum declaration:
enum class Fourcc
{
    /// RGB 24bit pixel format.
    RGB24 = MAKE_FOURCC_CODE('R', 'G', 'B', '3'),
    /// BGR 24bit pixel format.
    BGR24 = MAKE_FOURCC_CODE('B', 'G', 'R', '3'),
    /// YUYV 16bits per pixel format.
    YUYV  = MAKE_FOURCC_CODE('Y', 'U', 'Y', 'V'),
    /// UYVY 16bits per pixel format.
    UYVY  = MAKE_FOURCC_CODE('U', 'Y', 'V', 'Y'),
    /// Grayscale 8bit.
    GRAY  = MAKE_FOURCC_CODE('G', 'R', 'A', 'Y'),
    /// YUV 24bit per pixel format.
    YUV24  = MAKE_FOURCC_CODE('Y', 'U', 'V', '3'),
    /// NV12 pixel format.
    NV12  = MAKE_FOURCC_CODE('N', 'V', '1', '2'),
    /// NV21 pixel format.
    NV21  = MAKE_FOURCC_CODE('N', 'V', '2', '1'),
    /// YU12 (YUV420) - Planar pixel format.
    YU12 = MAKE_FOURCC_CODE('Y', 'U', '1', '2'),
    /// YV12 (YVU420) - Planar pixel format.
    YV12 = MAKE_FOURCC_CODE('Y', 'V', '1', '2'),
    /// JPEG compressed format.
    JPEG  = MAKE_FOURCC_CODE('J', 'P', 'E', 'G'),
    /// H264 compressed format.
    H264  = MAKE_FOURCC_CODE('H', '2', '6', '4'),
    /// HEVC compressed format.
    HEVC  = MAKE_FOURCC_CODE('H', 'E', 'V', 'C')
};
Table 3 - Bytes layout of supported pixel formats. Example of 4x4 pixels image.
 RGB24 |  BGR24 |
|---|---|
 YUV24 |
Library Principles
The library runs neural network models for object detection with ONNX Runtime. The algorithm consists of the following steps:
- The library converts the input frame to the input format and size of the neural network model itself, so the caller does not preprocess frames.
- After the inference session is created, input frames are forwarded directly into the ONNX Runtime session, utilizing neural network models for object detection.
- Computing results in output tensor, which is converted (according to detector parameters) to the final vector of objects.
- Results store not only coordinates but also probability and type - which can be assigned to particular item, according to current network labels.
The library is available as source code only. To utilize the library as source code, developers must include the library’s files into their project. The recommended usage sequence for the library is as follows:
- Integration: Include the library files in your project.
- Initialization: Create an instance of the
DnnOnnxDetectorC++ class for each camera or input source you wish to process. The library supports multiple instances for parallel camera processing. - Customization: If needed, you can customize the library’s behavior by using the
setParam()method. This allows you to adapt the library to specific requirements. - Object Detection: Create a
Frameobject to represent the input frame, and prepare a vector to store the detected objects. - Detection Process: Call the
detect(...)method to initiate the object detection process. - Object Retrieval: Retrieve the detected objects by using the
getObjects()method. The library provides a vector ofObjectscontaining information about the detected objects, such as their positions and attributes.
DnnOnnxDetector class description
DnnOnnxDetector class declaration
DnnOnnxDetector.h file contains DnnOnnxDetector class declaration. DnnOnnxDetector class inherits interface from ObjectDetector interface class. Class declaration:
class DnnOnnxDetector : public ObjectDetector
{
public:

    /// Class constructor.
    DnnOnnxDetector();

    /// Class destructor.
    ~DnnOnnxDetector() override;

    /// Copy and move operations are deleted.
    DnnOnnxDetector(const DnnOnnxDetector&) = delete;
    DnnOnnxDetector(DnnOnnxDetector&&) = delete;
    DnnOnnxDetector& operator= (const DnnOnnxDetector&) = delete;
    DnnOnnxDetector& operator= (DnnOnnxDetector&&) = delete;

    /// Get string of current library version.
    static std::string getVersion();

    /// Init object detector.
    bool initObjectDetector(ObjectDetectorParams& params) override;

    /// Set object detector param.
    bool setParam(ObjectDetectorParam id, float value) override;

    /// Get object detector param value.
    float getParam(ObjectDetectorParam id) override;

    /// Get object detector params structure.
    void getParams(ObjectDetectorParams& params) override;

    /// Get list of objects.
    std::vector<Object> getObjects() override;

    /// Execute command.
    bool executeCommand(ObjectDetectorCommand id) override;

    /// Perform detection.
    bool detect(rapidpixel::Frame& frame) override;

    /// Set detection mask.
    bool setMask(rapidpixel::Frame mask) override;

    /// Decode command and execute command.
    bool decodeAndExecuteCommand(uint8_t* data, int size) override;
};
Thread safety: initObjectDetector(…) and detect(…) are serialized by the class: a call waits until the previous call of one of these two methods is finished. All the other methods are thread-safe and do not wait for a running detect(…) call. The class does not write to the console or to a file. The first model that is loaded in the process sets the environment variable ORT_DISABLE_TELEMETRY (see section Build and connect to your project): other threads must not read or change the environment of the process during the first initObjectDetector(…) or detect(…) call, because setting an environment variable is not thread-safe.
getVersion method
The getVersion() method returns string of current version of DnnOnnxDetector class. Method declaration:
static std::string getVersion();
Method can be used without DnnOnnxDetector class instance. Example:
std::cout << "DnnOnnxDetector version: " << rapidpixel::DnnOnnxDetector::getVersion() << std::endl;
Console output:
DnnOnnxDetector version: 1.0.1
initObjectDetector method
The initObjectDetector(…) method initializes object detector. The method checks the initialization string (field initString of ObjectDetectorParams class), loads the neural network model and creates the inference session at once (it can take some time). If the initialization string is correct, the model is valid and the session is created, the method returns TRUE. The session is created for the execution provider selected by the type field (see the TYPE param): if the OpenVINO plugin library or the device is not found, or OpenVINO can not run a node of the model, the method returns FALSE and there is no fallback to CPU (see section OpenVINO execution provider). The initialization string has the format “model;width;height” or “model;weights;width;height”. The model is a path to a file in UTF-8. The weights item is accepted for compatibility with other detectors and is not used: ONNX Runtime reads the weights from the model file. ONNX Runtime parses the model file, so load models from trusted sources only. The width and the height of the network input are decimal numbers from 1 to 8192 without any other characters, and width * height must not be greater than 16777216 (4096 x 4096). The model must have one input with the shape [1, 3, height, width] and one output (see detect method). A model with dynamic input dimensions is also accepted. The initialization string must not contain the null character and must not be longer than 32768 bytes. If the method returns FALSE the detector is not initialized: detect(…) returns FALSE until the method succeeds. A detector that was never initialized uses the initialization string “thermal.onnx;640;640”. Method declaration:
bool initObjectDetector(ObjectDetectorParams& params) override;
| Parameter | Value |
|---|---|
| params | ObjectDetectorParams class object. The library takes into account only following parameters from ObjectDetectorParams class: initString classNames enable minObjectWidth (Value of a new detector 4) maxObjectWidth (Value of a new detector 256) minObjectHeight (Value of a new detector 4) maxObjectHeight (Value of a new detector 256) minDetectionProbability (Value of a new detector 0.5f) type (Value of a new detector 0) If a particular parameter is out of its valid range, the value is ignored and the current value of the parameter stays (see setParam method for the valid ranges). The exception is the type: a value that is not 0, 1, 2 or 3 makes the method return FALSE. The fields xDetectionCriteria, yDetectionCriteria and resetCriteria are not used by the method: these parameters are set by setParam(…) (the values of a new detector are 1 frame for the detection criteria and 10 frames for the reset criteria). |
Returns: TRUE if the object detector was initialized (initialization params are valid) or FALSE if not (wrong initialization string, wrong type, the model is not a file, can not be read, has not one input [1, 3, height, width] or has not one output, not enough memory). If FALSE is returned the parameters of the detector are not changed.
setParam method
The setParam(…) method is designed to set new DnnOnnxDetector object parameter value. Method declaration:
bool setParam(ObjectDetectorParam id, float value) override;
| Parameter | Description |
|---|---|
| id | Parameter ID according to ObjectDetectorParam enum. The library supports not all parameters from ObjectDetectorParam enum. |
| value | Parameter value. Value depends on parameter ID. The value of an integer parameter is truncated to the integer part. NaN, infinity and values outside of the valid range of the parameter are rejected. |
Returns: TRUE if the parameter was set or FALSE if not (not supported or out of valid range). If FALSE is returned the parameter is not changed.
getParam method
The getParam(…) method is designed to obtain object detector parameter value. Method declaration:
float getParam(ObjectDetectorParam id) override;
| Parameter | Description |
|---|---|
| id | Parameter ID according to ObjectDetectorParam enum. |
Returns: parameter value or -1.0f if the parameter is not supported by DnnOnnxDetector.
getParams method
The getParams(…) method is designed to obtain object detector params structures as well as a list of detected objects. Method declaration:
void getParams(ObjectDetectorParams& params) override;
| Parameter | Description |
|---|---|
| params | ObjectDetectorParams class object. The content is not defined if the memory is not available. |
getObjects method
The getObjects() method is designed to obtain list of detected objects. User can obtain list of detected objects via getParams(…) method as well. Method declaration:
std::vector<Object> getObjects() override;
Returns: list of detected objects (see Object structure description). If no objects are detected (or the memory is not available), the list will be empty.
executeCommand method
The executeCommand(…) method is designed to execute object detector command. Method declaration:
bool executeCommand(ObjectDetectorCommand id) override;
| Parameter | Description |
|---|---|
| id | Command ID according to ObjectDetectorCommand enum. |
Returns: TRUE if the command was executed or FALSE if not (only if command ID not valid).
detect method
The detect(…) method is designed to perform detection algorithm. Before transmitting the frame to ONNX Runtime, the method scales the frame to match the resolution of the neural network. Method declaration:
bool detect(rapidpixel::Frame& frame) override;
| Parameter | Description |
|---|---|
| frame | Video frame for processing. Object detector processes only BGR24, RGB24 and YUV24 pixel formats (see Frame class description). Size of frame must be from 32x32 to 8192x8192. The pointer to the data of the frame must be valid and the size of the data (field size) must be at least width * height * 3 bytes: the library can not check that the pointer is valid for the size. The frame is not changed. |
The neural network must have one output of the type float with the shape [1, 4 + C, N] (Ultralytics YOLOv8 layout), where C >= 1 is the number of classes and N <= 1048576 is the number of anchors. Rows 0 - 3 of the output hold the center X, the center Y, the width and the height of the box of an anchor in pixels of the network input, the following C rows hold the scores of the classes. Anchors with a not finite box value, a box larger than 1048576 pixels or a box with the width or the height less than 1 pixel are skipped. The first 16384 anchors (in the order of the output) with the best class score >= 0.3 are passed to the non-maximum suppression. The method returns at most 1024 objects (the objects with the highest probabilities). The field type of an object is the zero-based index of the class.
Returns: TRUE if the video frame was processed or FALSE if not (the detector is not initialized, the size or the data of the frame is not valid, the inference session can not be created or run, the output of the neural network has not the shape described above, not enough memory). Note: If object detector is disabled (see ObjectDetectorParam enum description), the frame has the size 0 or the pixel format of the frame is not supported, the frame is skipped: the list of objects is cleared and the method returns TRUE. If the size of the frame differs from the size of the previous frame the tracks of the objects are cleared (the inference session does not depend on the frame size). If initObjectDetector(…) was never called, the model of the default initialization string is loaded at the first frame.
setMask method
The setMask(…) method is designed to set detection mask. The user can disable detection in any areas of the video frame. For this purpose the user can create an image of any size and configuration with GRAY (preferable), NV12, NV21, YV12 or YU12 pixel format. Mask image pixel values equal to 0 prohibit detection of objects in the corresponding place of video frames. Any other mask pixel value other than 0 allows detection of objects at the corresponding location of video frames. The mask is used by the detector to skip objects whose bounding boxes fall on masked-out pixels. The method can be called either before video frame processing or during video frame processing. Method declaration:
bool setMask(rapidpixel::Frame mask) override;
| Parameter | Description |
|---|---|
| mask | Image of detection mask. Should have GRAY (preferable), NV12, NV21, YV12 or YU12 pixel format (see Frame description). Detector omits image segments where detection mask pixel values equal 0. Mask can have any resolution: it covers the whole video frame, and a pixel of the frame corresponds to the pixel of the mask with the same relative position (the resolution of the mask is not related to the resolution of the frame or of the neural network). An object is skipped if the mask value is 0 at the top-left or at the bottom-right pixel of its bounding box. The size of the data (field size) must be at least width * height bytes. The mask is copied. The parameter is passed by value (interface of ObjectDetector): the copy which the caller makes allocates the memory for the width and the height of the mask, also if the size of the data is smaller. The library checks the mask before it makes its own copy. |
Returns: TRUE if the mask is accepted or FALSE if not (not valid pixel format, empty, the size of the data is less than width * height, not enough memory).
decodeAndExecuteCommand method
The decodeAndExecuteCommand(…) method decodes and executes command which is encoded by encodeSetParamCommand(…) or encodeCommand(…) method of ObjectDetector class. decodeAndExecuteCommand(…) is a thread-safe method. This means that the decodeAndExecuteCommand(…) method can be safely called from any thread. Method declaration:
bool decodeAndExecuteCommand(uint8_t* data, int size) override;
| Parameter | Description |
|---|---|
| data | Pointer to input command. |
| size | Size of command. Must be 11 bytes for SET_PARAM or 7 bytes for COMMAND. |
Returns: TRUE if command decoded (SET_PARAM or COMMAND) and executed (action command or set param command) or FALSE if not (the pointer is nullptr, the size, the version or the ID of the command is not valid, the value of the parameter is rejected by setParam(…)).
encodeSetParamCommand method of ObjectDetector class
The encodeSetParamCommand(…) static method of the ObjectDetector interface designed to encode command to change any parameter for remote object detector (including motion detectors). To control object detector remotely, the developer has to design his own protocol and according to it encode the command and deliver it over the communication channel. To simplify this, the ObjectDetector class contains static methods for encoding the control command. The ObjectDetector class provides two types of commands: a parameter change command (SET_PARAM) and an action command (COMMAND). encodeSetParamCommand(…) designed to encode SET_PARAM command. Method declaration:
static void encodeSetParamCommand(uint8_t* data, int& size, ObjectDetectorParam id, float value);
| Parameter | Description |
|---|---|
| data | Pointer to data buffer for encoded command. Must have size >= 11. |
| size | Size of encoded data. Will be 11 bytes. |
| id | Parameter ID according to ObjectDetectorParam enum. |
| value | Parameter value. Value depends on parameter ID. |
encodeSetParamCommand(…) is static and used without ObjectDetector class instance. This method used on client side (control system). Command encoding example:
// Buffer for encoded data.
uint8_t data[11];
// Size of encoded data.
int size = 0;
// Random parameter value.
float outValue = static_cast<float>(std::rand() % 20);
// Encode command.
rapidpixel::ObjectDetector::encodeSetParamCommand(data, size, rapidpixel::ObjectDetectorParam::MIN_OBJECT_WIDTH, outValue);
encodeCommand method of ObjectDetector class
The encodeCommand(…) static method of the ObjectDetector interface designed to encode command for remote object detector (including motion detectors). To control object detector remotely, the developer has to design his own protocol and according to it encode the command and deliver it over the communication channel. To simplify this, the ObjectDetector class contains static methods for encoding the control command. The ObjectDetector class provides two types of commands: a parameter change command (SET_PARAM) and an action command (COMMAND). encodeCommand(…) designed to encode COMMAND (action command). Method declaration:
static void encodeCommand(uint8_t* data, int& size, ObjectDetectorCommand id);
| Parameter | Description |
|---|---|
| data | Pointer to data buffer for encoded command. Must have size >= 11. |
| size | Size of encoded data. Will be 11 bytes. |
| id | Command ID according to ObjectDetectorCommand enum. |
encodeCommand(…) is static and used without ObjectDetector class instance. This method used on client side (control system). Command encoding example:
// Buffer for encoded data.
uint8_t data[11];
// Size of encoded data.
int size = 0;
// Encode command.
rapidpixel::ObjectDetector::encodeCommand(data, size, rapidpixel::ObjectDetectorCommand::RESET);
decodeCommand method of ObjectDetector class
The decodeCommand(…) static method of the ObjectDetector interface designed to decode command on object detector side (edge device) encoded by encodeSetParamCommand(…) or encodeCommand(…) method of ObjectDetector class. Method declaration:
static int decodeCommand(uint8_t* data, int size, ObjectDetectorParam& paramId, ObjectDetectorCommand& commandId, float& value);
| Parameter | Description |
|---|---|
| data | Pointer to input command. |
| size | Size of command. Should be 11 bytes. |
| paramId | Parameter ID according to ObjectDetectorParam enum. After decoding SET_PARAM command the method will return parameter ID. |
| commandId | Command ID according to ObjectDetectorCommand enum. After decoding COMMAND the method will return command ID. |
| value | Parameter value (after decoding SET_PARAM command). |
Returns: 0 - in case decoding COMMAND, 1 - in case decoding SET_PARAM command or -1 in case errors.
Data structures
ObjectDetectorCommand enum
Enum declaration:
enum class ObjectDetectorCommand
{
    /// Reset.
    RESET = 1,
    /// Enable.
    ON,
    /// Disable.
    OFF
};
Table 4 - Object detector commands description. Some commands may be unsupported by particular object detector class.
| Command | Description |
|---|---|
| RESET | Reset algorithm. Clears the list of detected objects and resets all internal filters. |
| ON | Enable object detector. If the detector is not activated, frame processing is not performed - the list of detected objects will always be empty. |
| OFF | Disable object detector. If the detector is not activated, frame processing is not performed - the list of detected objects will always be empty. |
ObjectDetectorParam enum
Enum declaration:
enum class ObjectDetectorParam
{
    /// Logging mode. Values: 0 - Disable, 1 - Only file,
    /// 2 - Only terminal (console), 3 - File and terminal (console).
    LOG_MODE = 1,
    /// Frame buffer size. Depends on implementation.
    FRAME_BUFFER_SIZE,
    /// Minimum object width to be detected, pixels. To be detected object's
    /// width must be >= MIN_OBJECT_WIDTH.
    MIN_OBJECT_WIDTH,
    /// Maximum object width to be detected, pixels. To be detected object's
    /// width must be <= MAX_OBJECT_WIDTH.
    MAX_OBJECT_WIDTH,
    /// Minimum object height to be detected, pixels. To be detected object's
    /// height must be >= MIN_OBJECT_HEIGHT.
    MIN_OBJECT_HEIGHT,
    /// Maximum object height to be detected, pixels. To be detected object's
    /// height must be <= MAX_OBJECT_HEIGHT.
    MAX_OBJECT_HEIGHT,
    /// Minimum object's horizontal speed to be detected, pixels/frame. To be
    /// detected object's horizontal speed must be >= MIN_X_SPEED.
    MIN_X_SPEED,
    /// Maximum object's horizontal speed to be detected, pixels/frame. To be
    /// detected object's horizontal speed must be <= MAX_X_SPEED.
    MAX_X_SPEED,
    /// Minimum object's vertical speed to be detected, pixels/frame. To be
    /// detected object's vertical speed must be >= MIN_Y_SPEED.
    MIN_Y_SPEED,
    /// Maximum object's vertical speed to be detected, pixels/frame. To be
    /// detected object's vertical speed must be <= MAX_Y_SPEED.
    MAX_Y_SPEED,
    /// Probability threshold from 0 to 1. To be detected object detection
    /// probability must be >= MIN_DETECTION_PROBABILITY.
    MIN_DETECTION_PROBABILITY,
    /// Horizontal track detection criteria, frames. By default shows how many
    /// frames the objects must move in any(+/-) horizontal direction to be
    /// detected.
    X_DETECTION_CRITERIA,
    /// Vertical track detection criteria, frames. By default shows how many
    /// frames the objects must move in any(+/-) vertical direction to be
    /// detected.
    Y_DETECTION_CRITERIA,
    /// Track reset criteria, frames. By default shows how many
    /// frames the objects should be not detected to be excluded from results.
    RESET_CRITERIA,
    /// Detection sensitivity. Depends on implementation. Default from 0 to 1.
    SENSITIVITY,
    /// Frame scaling factor for processing purposes. Reduce the image size by
    /// scaleFactor times horizontally and vertically for faster processing.
    SCALE_FACTOR,
    /// Num threads. Number of threads for parallel computing.
    NUM_THREADS,
    /// Processing time of last frame in microseconds.
    PROCESSING_TIME_MCS,
    /// Algorithm type. Depends on implementation.
    TYPE,
    /// Mode. Default: 0 - Off, 1 - On.
    MODE,
    /// Custom parameter. Depends on implementation.
    CUSTOM_1,
    /// Custom parameter. Depends on implementation.
    CUSTOM_2,
    /// Custom parameter. Depends on implementation.
    CUSTOM_3
};
Table 5 - DnnOnnxDetector class params description (from ObjectDetector interface class). Some params are not supported by DnnOnnxDetector class.
| Parameter | Access | Description |
|---|---|---|
| LOG_MODE | read / write | Not used. Can have any value. |
| FRAME_BUFFER_SIZE | read / write | Not used. Can have any value. |
| MIN_OBJECT_WIDTH | read / write | Minimum object width to be detected, pixels of the video frame. Valid values from 1 to 8192. If it is greater than MAX_OBJECT_WIDTH no objects are detected. To be detected object’s width must be >= MIN_OBJECT_WIDTH. Default value is 4. |
| MAX_OBJECT_WIDTH | read / write | Maximum object width to be detected, pixels of the video frame. Valid values from 1 to 8192. If it is less than MIN_OBJECT_WIDTH no objects are detected. To be detected object’s width must be <= MAX_OBJECT_WIDTH. Default value is 256. |
| MIN_OBJECT_HEIGHT | read / write | Minimum object height to be detected, pixels of the video frame. Valid values from 1 to 8192. If it is greater than MAX_OBJECT_HEIGHT no objects are detected. To be detected object’s height must be >= MIN_OBJECT_HEIGHT. Default value is 4. |
| MAX_OBJECT_HEIGHT | read / write | Maximum object height to be detected, pixels of the video frame. Valid values from 1 to 8192. If it is less than MIN_OBJECT_HEIGHT no objects are detected. To be detected object’s height must be <= MAX_OBJECT_HEIGHT. Default value is 256. |
| MIN_X_SPEED | read / write | Not used. Can have any value. |
| MAX_X_SPEED | read / write | Not used. Can have any value. |
| MIN_Y_SPEED | read / write | Not used. Can have any value. |
| MAX_Y_SPEED | read / write | Not used. Can have any value. |
| MIN_DETECTION_PROBABILITY | read / write | Defines threshold for object detection probability. Only objects with probability greater than MIN_DETECTION_PROBABILITY will be detected. Can have any values from 0 to 1, but the detector discards the results with a probability below 0.3 before the threshold is applied, so a value below 0.3 gives the same result as 0.3. |
| X_DETECTION_CRITERIA | read / write | The same meaning as Y_DETECTION_CRITERIA. The number of video frames on which the object was detected so that it will be included in the list of detected objects. The library has detection counter for each object. After each detection the library increases detection counter for particular object. When detection counter >= X_DETECTION_CRITERIA, this object will be included into output detected objects list. If object not detected the library decreases detection counter. When user calls setParam(…) for X_DETECTION_CRITERIA, the Y_DETECTION_CRITERIA will be set automatically to the same value. Also method getParam(…) will return same value for X_DETECTION_CRITERIA and Y_DETECTION_CRITERIA. Valid values from 1 to 8192. |
| Y_DETECTION_CRITERIA | read / write | The same meaning as X_DETECTION_CRITERIA. The number of video frames on which the object was detected so that it will be included in the list of detected objects. The library has detection counter for each object. After each detection the library increases detection counter for particular object. When detection counter >= Y_DETECTION_CRITERIA, this object will be included into output detected objects list. If object not detected the library decreases detection counter. When user calls setParam(…) for Y_DETECTION_CRITERIA, the X_DETECTION_CRITERIA will be set automatically to the same value. Also method getParam(…) will return same value for X_DETECTION_CRITERIA and Y_DETECTION_CRITERIA. Valid values from 1 to 8192. |
| RESET_CRITERIA | read / write | The number of consecutive video frames in which the object was not detected, so it will be excluded from the internal object list. The internal object list is used to associate newly detected objects with objects detected in the previous video frame. Internal objects list allows the library to keep static object ID from frame to frame. If the object is not detected during a number of frames < RESET_CRITERIA, the next detection will not change the object ID. Valid values from 1 to 8192. |
| SENSITIVITY | read / write | Not used. Can have any value. |
| SCALE_FACTOR | read / write | Not used. Can have any value. |
| NUM_THREADS | read / write | Not used. Can have any value. |
| PROCESSING_TIME_MCS | read only | Read only. Stores processing time of current frame in microseconds. |
| TYPE | read / write | Type defines the execution provider of ONNX Runtime for neural network model computation. The value is used when the model is loaded, so it takes effect at the next call of initObjectDetector(…). - 0 - CPU (default) - 1 - OpenVINO, CPU - 2 - OpenVINO, the first GPU (integrated or discrete) - 3 - OpenVINO, the first discrete GPU OpenVINO is used through a plugin library, see section OpenVINO execution provider. If the plugin library or the device is not found, initObjectDetector(…) returns FALSE (there is no fallback to CPU). A value that is not 0, 1, 2 or 3 is rejected by setParam(…) and by initObjectDetector(…). |
| MODE | read / write | Mode: 0 - Off, 1 - On. The value of a new detector is 1 (On). If the detector is not activated, frame processing is not performed - the list of detected objects will always be empty. |
| CUSTOM_1 | read / write | Not used. Can have any value. |
| CUSTOM_2 | read / write | Not used. Can have any value. |
| CUSTOM_3 | read / write | Not used. Can have any value. |
Object structure
Object structure is used to describe detected object. Object structure declared in ObjectDetector.h file. Structure declaration:
typedef struct Object
{
    /// Object ID. Must be unique for particular object.
    int id{0};
    /// Frame ID. Must be the same as frame ID of processed video frame.
    int frameId{0};
    /// Object type. Depends on implementation.
    int type{0};
    /// Object rectangle width, pixels.
    int width{0};
    /// Object rectangle height, pixels.
    int height{0};
    /// Object rectangle top-left horizontal coordinate, pixels.
    int x{0};
    /// Object rectangle top-left vertical coordinate, pixels.
    int y{0};
    /// Horizontal component of object velocity, +-pixels/frame.
    float vX{0.0f};
    /// Vertical component of object velocity, +-pixels/frame.
    float vY{0.0f};
    /// Detection probability from 0 (minimum) to 1 (maximum).
    float p{0.0f};
} Object;
Table 6 - Object structure fields description.
| Field | Type | Description |
|---|---|---|
| id | int | Object ID. The library will try to keep the same object ID for particular object from frame to frame. |
| frameId | int | Frame ID. Will be the same as frame ID of processed video frame. |
| type | int | Object type: the zero-based index of the class (the row of the class scores in the output of the neural network). |
| width | int | Object rectangle width, pixels. Must be MIN_OBJECT_WIDTH <= width <= MAX_OBJECT_WIDTH (see ObjectDetectorParam enum description). |
| height | int | Object rectangle height, pixels. Must be MIN_OBJECT_HEIGHT <= height <= MAX_OBJECT_HEIGHT (see ObjectDetectorParam enum description). |
| x | int | Object rectangle top-left horizontal coordinate, pixels. |
| y | int | Object rectangle top-left vertical coordinate, pixels. |
| vX | float | Horizontal velocity of the object, pixels / frame (estimated by the tracker, 0 for a new object). |
| vY | float | Vertical velocity of the object, pixels / frame (estimated by the tracker, 0 for a new object). |
| p | float | Object detection probability (score). |
ObjectDetectorParams class description
ObjectDetectorParams class declaration
ObjectDetectorParams class used for object detector initialization (initObjectDetector(…) method) or to get all actual params (getParams() method) including list of detected objects. Also ObjectDetectorParams provides structure to write/read params from JSON files (JSON_READABLE macro, see ConfigReader class description) and provides methods to encode and decode params. Class declaration:
class ObjectDetectorParams
{
public:
    /// Init string. Depends on implementation. Must not contain the null
    /// character to be serialized by encode(...).
    std::string initString;
    /// Logging mode. Values:
    /// 0 - Disable,
    /// 1 - Only file,
    /// 2 - Only terminal (console),
    /// 3 - File and terminal (console).
    int logMode{0};
    /// Frame buffer size. Depends on implementation.
    int frameBufferSize{1};
    /// Minimum object width to be detected, pixels. To be detected object's
    /// width must be >= minObjectWidth.
    int minObjectWidth{4};
    /// Maximum object width to be detected, pixels. To be detected object's
    /// width must be <= maxObjectWidth.
    int maxObjectWidth{128};
    /// Minimum object height to be detected, pixels. To be detected object's
    /// height must be >= minObjectHeight.
    int minObjectHeight{4};
    /// Maximum object height to be detected, pixels. To be detected object's
    /// height must be <= maxObjectHeight.
    int maxObjectHeight{128};
    /// Minimum object's horizontal speed to be detected, pixels/frame. To be
    /// detected object's horizontal speed must be >= minXSpeed.
    float minXSpeed{0.0f};
    /// Maximum object's horizontal speed to be detected, pixels/frame. To be
    /// detected object's horizontal speed must be <= maxXSpeed.
    float maxXSpeed{30.0f};
    /// Minimum object's vertical speed to be detected, pixels/frame. To be
    /// detected object's vertical speed must be >= minYSpeed.
    float minYSpeed{0.0f};
    /// Maximum object's vertical speed to be detected, pixels/frame. To be
    /// detected object's vertical speed must be <= maxYSpeed.
    float maxYSpeed{30.0f};
    /// Probability threshold from 0 to 1. To be detected object detection
    /// probability must be >= minDetectionProbability.
    float minDetectionProbability{0.5f};
    /// Horizontal track detection criteria, frames. By default shows how many
    /// frames the objects must move in any(+/-) horizontal direction to be
    /// detected.
    int xDetectionCriteria{1};
    /// Vertical track detection criteria, frames. By default shows how many
    /// frames the objects must move in any(+/-) vertical direction to be
    /// detected.
    int yDetectionCriteria{1};
    /// Track reset criteria, frames. By default shows how many
    /// frames the objects should be not detected to be excluded from results.
    int resetCriteria{1};
    /// Detection sensitivity. Depends on implementation. Default from 0 to 1.
    float sensitivity{0.04f};
    /// Frame scaling factor for processing purposes. Reduce the image size by
    /// scaleFactor times horizontally and vertically for faster processing.
    int scaleFactor{1};
    /// Num threads. Number of threads for parallel computing.
    int numThreads{1};
    /// Processing time of last frame in microseconds.
    int processingTimeMcs{0};
    /// Algorithm / backend type. Depends on implementation.
    int type{0};
    /// Mode. Default: false - Off, true - On.
    bool enable{true};
    /// Custom parameter. Depends on implementation.
    float custom1{0.0f};
    /// Custom parameter. Depends on implementation.
    float custom2{0.0f};
    /// Custom parameter. Depends on implementation.
    float custom3{0.0f};
    /// List of detected objects.
    std::vector<Object> objects;
    /// A list of object class names used in detectors that recognize different
    /// object classes (see Table 7).
    std::vector<std::string> classNames{""};

    JSON_READABLE(ObjectDetectorParams, initString, logMode, frameBufferSize,
                  minObjectWidth, maxObjectWidth, minObjectHeight,
                  maxObjectHeight, minXSpeed, maxXSpeed, minYSpeed, maxYSpeed,
                  minDetectionProbability, xDetectionCriteria,
                  yDetectionCriteria, resetCriteria, sensitivity, scaleFactor,
                  numThreads, type, enable, custom1, custom2, custom3,
                  classNames)

    /// Default constructor and copy operations.
    ObjectDetectorParams() = default;
    ObjectDetectorParams(const ObjectDetectorParams& src) = default;
    ObjectDetectorParams& operator= (const ObjectDetectorParams& src) = default;

    /// Encode (serialize) params.
    bool encode(uint8_t* data, int bufferSize, int& size,
                ObjectDetectorParamsMask* mask = nullptr);

    /// Decode (deserialize) params encoded by encode(...) method.
    bool decode(uint8_t* data, int dataSize);
};
Table 7 - ObjectDetectorParams class fields description. Some params may be unsupported by DnnOnnxDetector class.
| Field | Type | Description |
|---|---|---|
| initString | string | Has to include path to neural network model in ONNX format that has standard one-batch layout. Also has to include dimension (width;height) of neural network input images, everything separated by semicolon. E.g.: “./model.onnx;640;640”. The format “model;weights;width;height” is also accepted, but the weights item is not used: ONNX Runtime reads the weights from the model file. The width and the height are decimal numbers from 1 to 8192. The model must have one input with the shape [1, 3, height, width] (dynamic dimensions are also accepted) and one output. The init string must not contain the null character and must not be longer than 32768 bytes. |
| logMode | int | Not used. Can have any value. |
| frameBufferSize | int | Not used. Can have any value. |
| minObjectWidth | int | Minimum object width to be detected, pixels of the video frame. Valid values from 1 to 8192. If it is greater than maxObjectWidth no objects are detected. To be detected object’s width must be >= minObjectWidth. Default value is 4. |
| maxObjectWidth | int | Maximum object width to be detected, pixels of the video frame. Valid values from 1 to 8192. If it is less than minObjectWidth no objects are detected. To be detected object’s width must be <= maxObjectWidth. Default value is 128. |
| minObjectHeight | int | Minimum object height to be detected, pixels of the video frame. Valid values from 1 to 8192. If it is greater than maxObjectHeight no objects are detected. To be detected object’s height must be >= minObjectHeight. Default value is 4. |
| maxObjectHeight | int | Maximum object height to be detected, pixels of the video frame. Valid values from 1 to 8192. If it is less than minObjectHeight no objects are detected. To be detected object’s height must be <= maxObjectHeight. Default value is 128. |
| minXSpeed | float | Not used. Can have any value. |
| maxXSpeed | float | Not used. Can have any value. |
| minYSpeed | float | Not used. Can have any value. |
| maxYSpeed | float | Not used. Can have any value. |
| minDetectionProbability | float | Defines threshold for object detection probability. Only objects with probability greater than MIN_DETECTION_PROBABILITY will be detected. Can have any values from 0 to 1, but the detector discards the results with a probability below 0.3 before the threshold is applied, so a value below 0.3 gives the same result as 0.3. |
| xDetectionCriteria | int | The same meaning as yDetectionCriteria. The number of video frames on which the object was detected so that it will be included in the list of detected objects. The library has detection counter for each object. After each detection the library increases detection counter for particular object. When detection counter >= xDetectionCriteria, this object will be included into output detected objects list. If object not detected the library decreases detection counter. When user calls setParam(…) for xDetectionCriteria, the yDetectionCriteria will be set automatically to the same value. Also method getParams(…) will return same value for xDetectionCriteria and yDetectionCriteria. Valid values from 1 to 8192. |
| yDetectionCriteria | int | The same meaning as xDetectionCriteria. The number of video frames on which the object was detected so that it will be included in the list of detected objects. The library has detection counter for each object. After each detection the library increases detection counter for particular object. When detection counter >= yDetectionCriteria, this object will be included into output detected objects list. If object not detected the library decreases detection counter. When user calls setParam(…) for yDetectionCriteria, the xDetectionCriteria will be set automatically to the same value. Also method getParams(…) will return same value for xDetectionCriteria and yDetectionCriteria. Valid values from 1 to 8192. |
| resetCriteria | int | The number of consecutive video frames in which the object was not detected, so it will be excluded from the internal object list. The internal object list is used to associate newly detected objects with objects detected in the previous video frame. Internal objects list allows the library to keep static object ID from frame to frame. If the object is not detected during a number of frames < resetCriteria, the next detection will not change the object ID. Valid values from 1 to 8192. |
| sensitivity | float | Not used. Can have any value. |
| scaleFactor | int | Not used. Can have any value. |
| numThreads | int | Not used. Can have any value. |
| processingTimeMcs | int | Read only. Stores processing time of current frame in microseconds. |
| type | int | Type defines the execution provider of ONNX Runtime for neural network model computation. The same values as the TYPE param of ObjectDetectorParam: - 0 - CPU (default) - 1 - OpenVINO, CPU - 2 - OpenVINO, the first GPU (integrated or discrete) - 3 - OpenVINO, the first discrete GPU Another value makes initObjectDetector(…) return FALSE. |
| enable | bool | Mode: false - Off, true - On. If the detector is not activated, frame processing is not performed - the list of detected objects will always be empty. |
| custom1 | float | Not used. Can have any value. |
| custom2 | float | Not used. Can have any value. |
| custom3 | float | Not used. Can have any value. |
| objects | std::vector | List of detected objects. |
| classNames | std::vector | A list of object class names used in detectors that recognize different object classes. Detected objects have an attribute called ‘type.’ If a detector doesn’t support object class recognition or can’t determine the object type, the ‘type’ field must be set to 0. Otherwise, the ‘type’ should correspond to the ordinal number of the class name from the ‘classNames’ list (if the list was set in params), starting from 1 (where the first element in the list has ‘type == 1’). DnnOnnxDetector sets the field type of an object to the zero-based index of the class: the class with the index 0 has type 0. |
Note: ObjectDetectorParams class fields listed in Table 7 must reflect params set/get by methods setParam(…) and getParam(…).
Serialize object detector params
ObjectDetectorParams class provides method encode(…) to serialize object detector params (fields of ObjectDetectorParams class, see Table 7). Serialization of object detector params is necessary when you need to send params via communication channels. Method provides options to exclude particular parameters from serialization. To do this, the method inserts a binary mask (4 bytes) where each bit represents a particular parameter and decode(…) method recognizes it. Method declaration:
bool encode(uint8_t* data, int bufferSize, int& size, ObjectDetectorParamsMask* mask = nullptr);
| Parameter | Value |
|---|---|
| data | Pointer to data buffer. Must not be nullptr. The pointer must be valid for bufferSize bytes (the library can not check this). |
| bufferSize | Size of data buffer, bytes. The buffer must hold all selected fields except the objects, the object counter, the init string and all class names with their null terminators: 102 bytes if all fields are selected, there are no objects, the init string is empty and the list of class names is the default list. If the data buffer size is not large enough to serialize all detected objects (40 bytes per object), only the objects which fit are included in the data. |
| size | Size of encoded data, bytes. 102 bytes by default. Set to 0 if the method returns FALSE. |
| mask | Parameters mask - pointer to ObjectDetectorParamsMask structure. ObjectDetectorParamsMask (declared in ObjectDetector.h file) determines flags for each field (parameter) declared in ObjectDetectorParams class. If the user wants to exclude any parameters from serialization, he can put a pointer to the mask. If the user wants to exclude a particular parameter from serialization, he should set the corresponding flag in the ObjectDetectorParamsMask structure. If the pointer is nullptr, all fields are encoded. |
Returns: TRUE if params encoded or FALSE if not (data is nullptr, the buffer is too small, the init string or a class name contains the null character, an empty class name is not the last one in the list). If FALSE is returned the content of the buffer is not defined.
ObjectDetectorParamsMask structure declaration:
struct ObjectDetectorParamsMask
{
    bool initString{ true };
    bool logMode{ true };
    bool frameBufferSize{ true };
    bool minObjectWidth{ true };
    bool maxObjectWidth{ true };
    bool minObjectHeight{ true };
    bool maxObjectHeight{ true };
    bool minXSpeed{ true };
    bool maxXSpeed{ true };
    bool minYSpeed{ true };
    bool maxYSpeed{ true };
    bool minDetectionProbability{ true };
    bool xDetectionCriteria{ true };
    bool yDetectionCriteria{ true };
    bool resetCriteria{ true };
    bool sensitivity{ true };
    bool scaleFactor{ true };
    bool numThreads{ true };
    bool processingTimeMcs{ true };
    bool type{ true };
    bool enable{ true };
    bool custom1{ true };
    bool custom2{ true };
    bool custom3{ true };
    bool objects{ true };
    bool classNames{ true };
};
Example without parameters mask:
// Prepare random params.
rapidpixel::ObjectDetectorParams in;
in.logMode = std::rand() % 255;
in.classNames = { "apple", "banana", "orange", "pineapple", "strawberry",
                  "watermelon", "lemon", "peach", "pear", "plum" };
for (int i = 0; i < 5; ++i)
{
    rapidpixel::Object obj;
    obj.id = std::rand() % 255;
    obj.type = std::rand() % 255;
    obj.width = std::rand() % 255;
    obj.height = std::rand() % 255;
    obj.x = std::rand() % 255;
    obj.y = std::rand() % 255;
    obj.vX = static_cast<float>(std::rand() % 255);
    obj.vY = static_cast<float>(std::rand() % 255);
    obj.p = static_cast<float>(std::rand() % 255);
    in.objects.push_back(obj);
}

// Encode data.
uint8_t data[1024];
int size = 0;
if (!in.encode(data, 1024, size))
{
    std::cout << "Can't encode data" << std::endl;
    return false;
}
std::cout << "Encoded data size: " << size << " bytes" << std::endl;
Example with parameters mask:
// Prepare random params.
rapidpixel::ObjectDetectorParams in;
in.logMode = std::rand() % 255;
in.classNames = { "apple", "banana", "orange", "pineapple", "strawberry",
                  "watermelon", "lemon", "peach", "pear", "plum" };
for (int i = 0; i < 5; ++i)
{
    rapidpixel::Object obj;
    obj.id = std::rand() % 255;
    obj.type = std::rand() % 255;
    obj.width = std::rand() % 255;
    obj.height = std::rand() % 255;
    obj.x = std::rand() % 255;
    obj.y = std::rand() % 255;
    obj.vX = static_cast<float>(std::rand() % 255);
    obj.vY = static_cast<float>(std::rand() % 255);
    obj.p = static_cast<float>(std::rand() % 255);
    in.objects.push_back(obj);
}

// Prepare mask.
rapidpixel::ObjectDetectorParamsMask mask;
mask.logMode = false;

// Encode data.
uint8_t data[1024];
int size = 0;
if (!in.encode(data, 1024, size, &mask))
{
    std::cout << "Can't encode data" << std::endl;
    return false;
}
std::cout << "Encoded data size: " << size << " bytes" << std::endl;
Deserialize object detector params
ObjectDetectorParams class provides method decode(…) to deserialize params (fields of ObjectDetectorParams class, see Table 7). Deserialization of params necessary in case when you need to receive params via communication channels. Method automatically recognizes which parameters were serialized by encode(…) method. The method checks the data type, the version, the size of the data before reading each field, the number of objects against the size of the data and that the init string and the class names are null terminated. The data must not have bytes after the last field. Fields which were not serialized are set to zero (empty for the string, the objects and the class names). The values of the fields are not checked against any range. Method declaration:
bool decode(uint8_t* data, int dataSize);
| Parameter | Value |
|---|---|
| data | Pointer to encoded data buffer. Must not be nullptr. The pointer must be valid for dataSize bytes (the library can not check this). |
| dataSize | Size of the encoded data, bytes. |
Returns: TRUE if data decoded (deserialized) or FALSE if not. If FALSE is returned the object is not changed.
Example:
// Prepare random params.
rapidpixel::ObjectDetectorParams in;
in.logMode = std::rand() % 255;
in.classNames = { "apple", "banana", "orange", "pineapple", "strawberry",
                  "watermelon", "lemon", "peach", "pear", "plum" };
for (int i = 0; i < 5; ++i)
{
    rapidpixel::Object obj;
    obj.id = std::rand() % 255;
    obj.type = std::rand() % 255;
    obj.width = std::rand() % 255;
    obj.height = std::rand() % 255;
    obj.x = std::rand() % 255;
    obj.y = std::rand() % 255;
    obj.vX = static_cast<float>(std::rand() % 255);
    obj.vY = static_cast<float>(std::rand() % 255);
    obj.p = static_cast<float>(std::rand() % 255);
    in.objects.push_back(obj);
}

// Encode data.
uint8_t data[1024];
int size = 0;
if (!in.encode(data, 1024, size))
{
    std::cout << "Can't encode data" << std::endl;
    return false;
}
std::cout << "Encoded data size: " << size << " bytes" << std::endl;

// Decode data.
rapidpixel::ObjectDetectorParams out;
if (!out.decode(data, size))
{
    std::cout << "Can't decode data" << std::endl;
    return false;
}
Read params from JSON file and write to JSON file
ObjectDetector library depends on ConfigReader library which provides methods to read params from JSON file and to write params to JSON file. Example of writing and reading params to JSON file:
// Prepare random params.
rapidpixel::ObjectDetectorParams in;
in.logMode = std::rand() % 255;
in.classNames = { "apple", "banana", "orange", "pineapple", "strawberry",
                  "watermelon", "lemon", "peach", "pear", "plum" };
for (int i = 0; i < 5; ++i)
{
    rapidpixel::Object obj;
    obj.id = std::rand() % 255;
    obj.type = std::rand() % 255;
    obj.width = std::rand() % 255;
    obj.height = std::rand() % 255;
    obj.x = std::rand() % 255;
    obj.y = std::rand() % 255;
    obj.vX = static_cast<float>(std::rand() % 255);
    obj.vY = static_cast<float>(std::rand() % 255);
    obj.p = static_cast<float>(std::rand() % 255);
    in.objects.push_back(obj);
}

// Write params to file.
rapidpixel::ConfigReader inConfig;
inConfig.set(in, "ObjectDetectorParams");
if (!inConfig.writeToFile("ObjectDetectorParams.json"))
{
    std::cout << "Can't write config file" << std::endl;
    return false;
}

// Read params from file.
rapidpixel::ConfigReader outConfig;
if (!outConfig.readFromFile("ObjectDetectorParams.json"))
{
    std::cout << "Can't open config file" << std::endl;
    return false;
}

rapidpixel::ObjectDetectorParams out;
if (!outConfig.get(out, "ObjectDetectorParams"))
{
    std::cout << "Can't read params from file" << std::endl;
    return false;
}
ObjectDetectorParams.json will look like:
{
    "ObjectDetectorParams": {
        "classNames": [
            "apple",
            "banana",
            "orange",
            "pineapple",
            "strawberry",
            "watermelon",
            "lemon",
            "peach",
            "pear",
            "plum"
        ],
        "custom1": 57.0,
        "custom2": 244.0,
        "custom3": 68.0,
        "enable": false,
        "frameBufferSize": 200,
        "initString": "sfsfsfsfsf",
        "logMode": 111,
        "maxObjectHeight": 103,
        "maxObjectWidth": 199,
        "maxXSpeed": 104.0,
        "maxYSpeed": 234.0,
        "minDetectionProbability": 53.0,
        "minObjectHeight": 191,
        "minObjectWidth": 149,
        "minXSpeed": 213.0,
        "minYSpeed": 43.0,
        "numThreads": 33,
        "resetCriteria": 62,
        "scaleFactor": 85,
        "sensitivity": 135.0,
        "type": 178,
        "xDetectionCriteria": 224,
        "yDetectionCriteria": 199
    }
}
Build and connect to your project
A necessary step before building DnnOnnxDetector library is to download the ONNX Runtime package. Go to the ONNX Runtime releases page and download the package for your platform and operating system (for example *onnxruntime-win-x64-
- Windows: copy the DLL files (onnxruntime.dll and onnxruntime_providers_shared.dll) from the folder lib of the package next to the executable files. Otherwise Windows can load another onnxruntime.dll (for example from C:\Windows\System32) of a wrong version.
- Linux: nothing has to be copied. The build writes the path of the folder lib of the package into the executable files (RUNPATH), so do not move or delete the package folder after the build.
The official ONNX Runtime packages collect telemetry and send it to the manufacturer of ONNX Runtime by default (see the file Privacy.md of the package): the first environment of ONNX Runtime in a process stores an identifier of the computer and a queue of events in the user folder, and the events are sent over the network. The library switches the telemetry off before the first model is loaded in the process: it sets the environment variable ORT_DISABLE_TELEMETRY to 1 (if the process does not have this variable) before it creates the environment of ONNX Runtime, and switches off the telemetry events of the environment. ONNX Runtime has one environment per process: if the application uses ONNX Runtime by itself and creates an environment before the first detector loads a model, the application has to set the variable before (or use a build of ONNX Runtime without telemetry), otherwise ONNX Runtime stores the identifier and sends the initialization event.
Step by step guide (Windows and Linux): GETTING_STARTED.md.
The OpenVINO execution provider (Intel CPU and GPU) needs an additional plugin library, see section OpenVINO execution provider.
Build stand alone
The repository does not contain sub-repositories. The libraries DnnOnnxDetector depends on (ObjectDetector, ImageResizer, FormatConverter and the libraries they depend on: Frame, ConfigReader) must be cloned into the same folder as DnnOnnxDetector. The demo application, the example and the benchmark use more libraries (VSource, VCodec, VDecoderH264, VDecoderH265, VDecoderJPEG, VSourceFile, SimpleUI, SimpleFileDialog, VideoRecorderMp4, VEncoderJPEG): they are needed only if these applications are built. The folder structure must be:
<work folder>
    DnnOnnxDetector
    Frame
    ConfigReader
    ObjectDetector
    ImageResizer
    FormatConverter
    VSource               (demo, example, benchmark)
    VCodec                (demo, example, benchmark)
    VDecoderH264          (demo, example, benchmark)
    VDecoderH265          (demo, example, benchmark)
    VDecoderJPEG          (demo, example, benchmark)
    VSourceFile           (demo, example, benchmark)
    SimpleUI              (demo, example)
    SimpleFileDialog      (demo)
    VideoRecorderMp4      (demo)
    VEncoderJPEG          (demo)
Typical commands to build the library only (use the URLs of the repositories provided to you):
git clone <DnnOnnxDetector repository URL>
git clone <Frame repository URL>
git clone <ConfigReader repository URL>
git clone <ObjectDetector repository URL>
git clone <ImageResizer repository URL>
git clone <FormatConverter repository URL>
cd DnnOnnxDetector
mkdir build
cd build
cmake .. -D_SUBMODULE_CACHE_OVERWRITE=OFF -D_DNN_ONNX_DETECTOR_BENCHMARK=OFF -D_DNN_ONNX_DETECTOR_DEMO=OFF -D_DNN_ONNX_DETECTOR_EXAMPLE=OFF -D CMAKE_PREFIX_PATH=<ONNX Runtime folder>
cmake --build . --config Release
To build the library, the demo application, the example and the benchmark, clone all the repositories listed above and follow the step by step guide GETTING_STARTED.md (Windows and Linux). On Linux the SimpleUI library uses the X11 library (packages libx11-dev and libxext-dev on Ubuntu). If DnnOnnxDetector is the top-level CMake project, the main CMakeLists.txt file adds the folders ../Frame, ../ConfigReader, ../ObjectDetector, ../ImageResizer and ../FormatConverter (in this order) before the library itself, and the folders of the libraries of the demo application, the example and the benchmark before these applications. If a folder does not exist CMake stops with an error.
CMake options
Table 8 - CMake options of the repository. In the options below ${PARENT} is the prefix defined by the top-level project (empty if DnnOnnxDetector is the top-level project).
| Option | Default | Description |
|---|---|---|
| ${PARENT}_DNN_ONNX_DETECTOR | ON | Build the library. |
| ${PARENT}_DNN_ONNX_DETECTOR_BENCHMARK | ON (stand alone), OFF (included in other project) | Build the benchmark. |
| ${PARENT}_DNN_ONNX_DETECTOR_DEMO | ON (stand alone), OFF (included in other project) | Build the demo application. |
| ${PARENT}_DNN_ONNX_DETECTOR_EXAMPLE | ON (stand alone), OFF (included in other project) | Build the example. |
| ${PARENT}_SUBMODULE_CACHE_OVERWRITE | ON | Forced rewriting of the options above in the CMake cache. With the value ON an option set by -D on the command line is overwritten: set it to OFF to change the options above. The top-level project sets it to OFF when it includes DnnOnnxDetector as a sub-repository. |
| CMAKE_BUILD_TYPE | Release (if not specified) | Build type. |
| CMAKE_PREFIX_PATH | not set | Folder of the ONNX Runtime package (see above). |
Connect to your project
If you want to connect DnnOnnxDetector library to your CMake project as source code, you can do the following. For example, if your repository has structure:
CMakeLists.txt
src
    CMakeList.txt
    yourLib.h
    yourLib.cpp
Create 3rdparty folder in your repository. Copy the repositories DnnOnnxDetector, Frame, ConfigReader, ObjectDetector, ImageResizer and FormatConverter to 3rdparty folder. Remember to specify the path to the ONNX Runtime package (CMAKE_PREFIX_PATH) as described above. The OpenVINO plugin library is not needed at build time: it is found at run time (see section OpenVINO execution provider). The new structure of your repository will be as follows:
CMakeLists.txt
src
    CMakeList.txt
    yourLib.h
    yourLib.cpp
3rdparty
    DnnOnnxDetector
    Frame
    ConfigReader
    ObjectDetector
    ImageResizer
    FormatConverter
Create CMakeLists.txt file in 3rdparty folder. The libraries must be added in the order of their dependencies: the library DnnOnnxDetector does not add its dependencies when it is included in another project. If a dependency is not added by the project, the compilation of the library stops with an error like Cannot open include file: ‘ObjectDetector.h’: No such file or directory. CMakeLists.txt should be containing:
cmake_minimum_required(VERSION 3.13)

################################################################################
## 3RD-PARTY
## dependencies for the project
################################################################################
project(3rdparty LANGUAGES CXX)

################################################################################
## SETTINGS
## basic 3rd-party settings before use
################################################################################
# To inherit the top-level architecture when the project is used as a submodule.
SET(PARENT ${PARENT}_YOUR_PROJECT_3RDPARTY)
# Disable self-overwriting of parameters inside included subdirectories.
SET(${PARENT}_SUBMODULE_CACHE_OVERWRITE OFF CACHE BOOL "" FORCE)

################################################################################
## CONFIGURATION
## 3rd-party submodules configuration
################################################################################
SET(${PARENT}_SUBMODULE_FRAME                           ON  CACHE BOOL "" FORCE)
if (${PARENT}_SUBMODULE_FRAME)
    SET(${PARENT}_FRAME                                 ON  CACHE BOOL "" FORCE)
    SET(${PARENT}_FRAME_TEST                            OFF CACHE BOOL "" FORCE)
endif()

SET(${PARENT}_SUBMODULE_CONFIG_READER                   ON  CACHE BOOL "" FORCE)
if (${PARENT}_SUBMODULE_CONFIG_READER)
    SET(${PARENT}_CONFIG_READER                         ON  CACHE BOOL "" FORCE)
    SET(${PARENT}_CONFIG_READER_EXAMPLES                OFF CACHE BOOL "" FORCE)
    SET(${PARENT}_CONFIG_READER_TESTS                   OFF CACHE BOOL "" FORCE)
endif()

SET(${PARENT}_SUBMODULE_OBJECT_DETECTOR                 ON  CACHE BOOL "" FORCE)
if (${PARENT}_SUBMODULE_OBJECT_DETECTOR)
    SET(${PARENT}_OBJECT_DETECTOR                       ON  CACHE BOOL "" FORCE)
    SET(${PARENT}_OBJECT_DETECTOR_TEST                  OFF CACHE BOOL "" FORCE)
    SET(${PARENT}_OBJECT_DETECTOR_EXAMPLE               OFF CACHE BOOL "" FORCE)
endif()

SET(${PARENT}_SUBMODULE_IMAGE_RESIZER                   ON  CACHE BOOL "" FORCE)
if (${PARENT}_SUBMODULE_IMAGE_RESIZER)
    SET(${PARENT}_IMAGE_RESIZER                         ON  CACHE BOOL "" FORCE)
    SET(${PARENT}_IMAGE_RESIZER_EXAMPLE                 OFF CACHE BOOL "" FORCE)
endif()

SET(${PARENT}_SUBMODULE_FORMAT_CONVERTER                ON  CACHE BOOL "" FORCE)
if (${PARENT}_SUBMODULE_FORMAT_CONVERTER)
    SET(${PARENT}_FORMAT_CONVERTER                      ON  CACHE BOOL "" FORCE)
    SET(${PARENT}_FORMAT_CONVERTER_BENCHMARK            OFF CACHE BOOL "" FORCE)
endif()

SET(${PARENT}_SUBMODULE_DNN_ONNX_DETECTOR           ON  CACHE BOOL "" FORCE)
if (${PARENT}_SUBMODULE_DNN_ONNX_DETECTOR)
    SET(${PARENT}_DNN_ONNX_DETECTOR                 ON  CACHE BOOL "" FORCE)
    SET(${PARENT}_DNN_ONNX_DETECTOR_BENCHMARK       OFF CACHE BOOL "" FORCE)
    SET(${PARENT}_DNN_ONNX_DETECTOR_DEMO            OFF CACHE BOOL "" FORCE)
    SET(${PARENT}_DNN_ONNX_DETECTOR_EXAMPLE         OFF CACHE BOOL "" FORCE)
endif()

################################################################################
## INCLUDING SUBDIRECTORIES
## Adding subdirectories according to the 3rd-party configuration
################################################################################
if (${PARENT}_SUBMODULE_FRAME)
    add_subdirectory(Frame)
endif()

if (${PARENT}_SUBMODULE_CONFIG_READER)
    add_subdirectory(ConfigReader)
endif()

if (${PARENT}_SUBMODULE_OBJECT_DETECTOR)
    add_subdirectory(ObjectDetector)
endif()

if (${PARENT}_SUBMODULE_IMAGE_RESIZER)
    add_subdirectory(ImageResizer)
endif()

if (${PARENT}_SUBMODULE_FORMAT_CONVERTER)
    add_subdirectory(FormatConverter)
endif()

if (${PARENT}_SUBMODULE_DNN_ONNX_DETECTOR)
    add_subdirectory(DnnOnnxDetector)
endif()
File 3rdparty/CMakeLists.txt adds the libraries to your project and excludes test applications and examples from compiling (by default test applications and examples are excluded from compiling if a library is included as sub-repository). The new structure of your repository:
CMakeLists.txt
src
    CMakeList.txt
    yourLib.h
    yourLib.cpp
3rdparty
    CMakeLists.txt
    DnnOnnxDetector
    Frame
    ConfigReader
    ObjectDetector
    ImageResizer
    FormatConverter
Next, you need to include the ‘3rdparty’ folder in the main CMakeLists.txt file of your repository. Add the following string at the end of your main CMakeLists.txt:
add_subdirectory(3rdparty)
Next, you have to include DnnOnnxDetector library in your src/CMakeLists.txt file:
target_link_libraries(${PROJECT_NAME} DnnOnnxDetector)
Done!
Link ONNX Runtime in a VisualStudio project on Windows
-
In Properties, go to VC++ Directories -> General -> Include Directories -> Edit and add the ONNX Runtime include directory:
C:\work\onnxruntime-win-x64-1.31.0\include -
In Properties, go to VC++ Directories -> General -> Library Directories -> Edit and add the ONNX Runtime lib directory:
C:\work\onnxruntime-win-x64-1.31.0\lib -
In Properties, go to Linker -> Input -> Additional Dependencies -> Edit and add lib file:
onnxruntime.lib -
Copy the DLL files (onnxruntime.dll and onnxruntime_providers_shared.dll) from the folder C:\work\onnxruntime-win-x64-1.31.0\lib next to the executable file.
Link ONNX Runtime in a Qt Creator project on Windows
-
To include headers, edit the YourProject.pro file by adding:
INCLUDEPATH += C:\work\onnxruntime-win-x64-1.31.0\include (Example) -
Specify lib files:
LIBS += C:\work\onnxruntime-win-x64-1.31.0\lib\onnxruntime.lib -
Copy the DLL files (onnxruntime.dll and onnxruntime_providers_shared.dll) from the folder C:\work\onnxruntime-win-x64-1.31.0\lib next to the executable file.
OpenVINO execution provider
The library can run the neural network on Intel CPUs and GPUs with the OpenVINO execution provider of ONNX Runtime (values 1, 2 and 3 of the TYPE param, see ObjectDetectorParam). The execution provider is not a part of the ONNX Runtime package from the releases page: it is a separate plugin library, which the library registers in ONNX Runtime at run time. The ONNX Runtime package and the build of the library stay the same (ONNX Runtime 1.23 or newer is required for any build of the library), CMake does not need any option. The plugin library is distributed in the NuGet package Intel.ML.OnnxRuntime.EP.OpenVINO (Windows x64 and Linux x64). The execution provider can be used on Windows and Linux only: the library finds the folder of the executable file with the Windows function GetModuleFileNameW or with /proc/self/exe on Linux. The package already contains the OpenVINO runtime, so OpenVINO does not have to be installed.
Use version 1.6.1 of the package with ONNX Runtime 1.31.0. Versions 1.7.0 and 1.8.0 use an experimental function that the official ONNX Runtime 1.31.0 does not have: the library is registered and the devices are listed, but the creation of the session fails (the detector is not initialized).
Get the plugin library:
- Download the file intel.ml.onnxruntime.ep.openvino.1.6.1.nupkg from the page of the package (Download package) and rename it to .zip, or download it directly: https://api.nuget.org/v3-flatcontainer/intel.ml.onnxruntime.ep.openvino/1.6.1/intel.ml.onnxruntime.ep.openvino.1.6.1.nupkg.
- Unzip it. The folder runtimes/win-x64/native (Windows) or runtimes/linux-x64/native (Linux) contains the plugin library (onnxruntime_providers_openvino_plugin.dll or libonnxruntime_providers_openvino_plugin.so) and the OpenVINO libraries it needs. Keep all the files of this folder together and copy all of them, not only the DLL files (on Windows the file openvino_runtime.manifest is needed too: without it the plugin library fails to load with the error “side-by-side configuration is incorrect”).
Put the plugin library next to the executable file. Copy all the files of the folder native to the folder of the executable file (for the applications of the repository: build\bin\Release on Windows, build/bin on Linux). The library loads the plugin library only from the folder of the executable file: it does not use an environment variable, the current folder, PATH or LD_LIBRARY_PATH. The plugin library is registered once per process (ONNX Runtime has one environment per process): the detectors of the process share it, and if the application has registered the OpenVINO execution provider by itself, the library uses it. If the file onnxruntime_providers_openvino_plugin.dll (Windows) or libonnxruntime_providers_openvino_plugin.so (Linux) is not in this folder, initObjectDetector(…) returns FALSE. On Linux the plugin and the OpenVINO libraries look for each other in their own folder (RUNPATH $ORIGIN), so nothing else is needed.
Linux, GPU (TYPE 2 and 3): the packages ocl-icd-libopencl1, intel-opencl-icd, libze1 and libze-intel-gpu1 must be installed (libze1 is only the Level Zero loader, the Intel GPU driver is libze-intel-gpu1). The CPU (TYPE 0 and 1) does not need them. WSL2 can not use the GPU types: ONNX Runtime does not detect any GPU there, so TYPE 2 and 3 fail on WSL2 even with the packages (OpenVINO itself sees the GPUs, but the plugin has no GPU to select).
Select the device with the TYPE param (field type of ObjectDetectorParams, see also ObjectDetectorParam): 1 - OpenVINO CPU, 2 - OpenVINO on the first GPU, 3 - OpenVINO on the first discrete GPU (0 is the CPU of ONNX Runtime without OpenVINO). The device is selected by its kind and not by its number, because the numbers of the GPUs depend on the computer (for example integrated GPU is GPU.0 and discrete GPU is GPU.1 in a computer with both). If the plugin library can not be loaded or the computer has no such device (for example no discrete GPU), initObjectDetector(…) returns FALSE: the library never falls back to CPU silently. For the same reason a model with a node (operator) that OpenVINO can not run does not fall back to the CPU for this node: the initialization fails. The OpenVINO optimizes the network by itself, so the graph optimization of ONNX Runtime is turned off for these devices. The first initialization on a GPU takes several seconds (OpenVINO compiles the network for the GPU).
Select the device in the applications of the repository: the benchmark asks for the type at the start, the example sets it in the line params.type of example/main.cpp (build again after the change), the demo application reads it from the field type of its JSON file. Step by step guide with the commands: step 10 of GETTING_STARTED.md.
The computation on a GPU can use lower precision than on CPU, so the detected objects can differ a little: in the test of section Portability the numbers of objects of the first 900 frames are equal on CPU (TYPE 0 and 1) and on the discrete GPU (TYPE 3), and differ in 16 frames on the integrated GPU (TYPE 2).
Portability
The library, the example, the benchmark and the demo application were built without warnings with the options of the CMake files (warning level 4 for MSVC, the warning options listed in the CMake files for GCC and Clang) and run on:
Tested execution providers (ONNX Runtime 1.31.0, thermal.onnx 640x640, test.mp4, the benchmark application, Windows 11 on a computer with a 13th Gen Intel Core i7-13700H, integrated Intel UHD Graphics and discrete Intel Arc A370M Graphics, and Linux in WSL2 (Windows: average of 200 frames; Linux: median of about 1350 frames, 40 seconds per type); the processing time per frame includes the pixel format conversion, the scaling and the post processing, and can change by several milliseconds from run to run):
| TYPE | Execution provider | Windows 11 x64 | Linux x64 (WSL2) |
|---|---|---|---|
| 0 | CPU (built-in) | works, about 28 ms | works, about 28 ms |
| 1 | OpenVINO plugin 1.6.1, CPU | works, about 36 ms | works, about 26 ms (the first 3 frames 88, 51 and 47 ms: OpenVINO compiles the model); the numbers of objects are the same as on CPU in every frame |
| 2 | OpenVINO plugin 1.6.1, the first GPU (integrated) | works, about 10 ms | not available in WSL2: ONNX Runtime detects no GPU there (Can’t init detector). The GPU needs native Linux with the Intel GPU driver, see section OpenVINO execution provider |
| 3 | OpenVINO plugin 1.6.1, the first discrete GPU | works, about 9 ms | not available in WSL2 (the same reason as TYPE 2) |
Tested build environments and versions:
| Platform | Compiler | CMake | ONNX Runtime | OpenVINO plugin |
|---|---|---|---|---|
| Windows 11 x64 | Visual Studio 2026 (MSVC 19.51) | 4.4.2 | 1.31.0 | 1.6.1 (1.7.0 and 1.8.0 do not work with ONNX Runtime 1.31.0) |
| Linux x64, Ubuntu 24.04 in WSL2 | GCC 13.3.0 | 3.28.3 | 1.31.0 | 1.6.1 |
| Linux x64, Ubuntu 24.04 in WSL2 | GCC 12.4.0, Clang 15.0.7, Clang 18.1.3 (TYPE 0 only) | 3.28.3 | 1.31.0 | - |
| Linux aarch64 (cross build with GCC 13.3.0, run in the emulator qemu) | GCC 13.3.0 | 3.28.3 | 1.31.0 (linux-aarch64 package) | - |
The other versions of ONNX Runtime were not tested.
The encoded params and commands store the integer and float values (4 bytes, checked by the compiler) in the byte order of the host: the encoded data can be exchanged between hosts of the same byte order only. The library itself has no CPU specific code: the libraries ImageResizer and FormatConverter select the SIMD instructions at run time.
Example
A simple application shows how to use the DnnOnnxDetector library. The application opens a video file “test.mp4” (it must be in the working directory, the file is located in the /static folder) and copies the video frame data into an object of the Frame class and performs object detection. The model “thermal.onnx” must be in the working directory too (the file is located in the /static folder). The application checks the result of every call of the libraries: it ends with an error message if the video file can not be opened, the detector can not be initialized or 10 frames in a row can not be captured or processed. The application ends when the ESC key is pressed or the window is closed. The example uses the CPU: to use OpenVINO, change the value of params.type in the code below (see section OpenVINO execution provider).
#include <iostream>
#include <string>
#include <vector>
#include "DnnOnnxDetector.h"
#include "SimpleUi.h"
#include "VSourceFile.h"


/// Maximum number of consecutive frames that can not be captured or
/// processed. The example stops after that: a broken video file or model does
/// not make it wait forever.
constexpr int MAX_FAILURES{10};


int main()
{
    // Open video file "test.mp4" (playback is looped by the video source).
    rapidpixel::VSourceFile videoSource;
    std::string videoFile = "test.mp4";
    if (!videoSource.openVSource(videoFile))
    {
        std::cout << "Can't open video file " << videoFile << std::endl;
        return 1;
    }

    // Create and init detector.
    rapidpixel::DnnOnnxDetector detector;
    rapidpixel::ObjectDetectorParams params;
    params.initString = "./thermal.onnx;640;640";
    params.maxObjectHeight = 256;
    params.maxObjectWidth = 256;
    params.minObjectHeight = 4;
    params.minObjectWidth = 4;
    // Execution provider: 0 - CPU, 1 - OpenVINO CPU, 2 - OpenVINO GPU,
    // 3 - OpenVINO discrete GPU (1, 2 and 3 need the OpenVINO plugin library,
    // see GETTING_STARTED.md).
    params.type = 0;
    if (!detector.initObjectDetector(params))
    {
        std::cout << "Can't init detector" << std::endl;
        return 1;
    }

    // Create window to show video.
    rapidpixel::SimpleUiWindow window("VIDEO");
    window.show();

    // Main loop.
    rapidpixel::VSourceParams videoParams;
    videoSource.getParams(videoParams);
    rapidpixel::Frame frameBgr(videoParams.width, videoParams.height,
                               rapidpixel::Fourcc::BGR24);
    if (frameBgr.data == nullptr)
    {
        std::cout << "Wrong video frame size" << std::endl;
        return 1;
    }
    const rapidpixel::Color red{255, 0, 0};
    int failures = 0;
    while (window.isOpen())
    {
        // Capture next video frame and detect objects.
        frameBgr.fourcc = rapidpixel::Fourcc::BGR24;
        if (!videoSource.getFrame(frameBgr, 1000) ||
            !detector.detect(frameBgr))
        {
            ++failures;
            if (failures >= MAX_FAILURES)
            {
                std::cout << "Can't capture or process video frames" <<
                             std::endl;
                return 1;
            }
            continue;
        }
        failures = 0;

        // Get list of objects.
        std::vector<rapidpixel::Object> objects = detector.getObjects();

        // Draw detected objects.
        for (size_t n = 0; n < objects.size(); ++n)
        {
            rapidpixel::SimpleUiDraw::drawRectangle(frameBgr, objects[n].x,
                objects[n].y, objects[n].x + objects[n].width - 1,
                objects[n].y + objects[n].height - 1, red, 1);
            rapidpixel::SimpleUiDraw::drawText(frameBgr, objects[n].x,
                objects[n].y - 14, std::to_string(objects[n].p), red, 14);
        }

        // Show video. ESC - exit.
        window.render(frameBgr);
        if (window.getKey(1) == 27)
        {
            return 0;
        }
    }

    return 0;
}
Benchmark
Benchmark application located in /benchmark folder and is intended to check performance (processing time per frame) on particular platform. After start user should enter initialization string (see ObjectDetectorParams class description). Benchmark application will load neural network and will open test.mp4 video file (must be placed in the working directory of the benchmark, the file is located in the /static folder; the model thermal.onnx from the same folder can be used for the initialization string). The benchmark application will show number of detected objects and processing time per frame (microseconds) until it is stopped by the user (for example with Ctrl+C). The inference session is created before the first frame, when the detector is initialized. The benchmark ends with an error message if the detector can not be initialized, the video file can not be opened or 10 frames in a row can not be captured or processed. Benchmark output example:
DnnOnnxDetector v1.0.1 benchmark

Set init string ('model;width;height'): thermal.onnx;640;640
Set detector type (0 - CPU, 1 - OpenVINO CPU, 2 - OpenVINO GPU, 3 - OpenVINO discrete GPU): 0
2 objects detected, time 36907 us
2 objects detected, time 37883 us
2 objects detected, time 33620 us
Demo application
Demo application overview
The demo application is intended to evaluate the performance of the DnnOnnxDetector C++ library. The application allows you to evaluate the detection algorithm with chosen video file. It is a console application and can be used as an example of DnnOnnxDetector library usage.
Launch and user interface
The demo application does not require installation. The demo application is compiled for Windows OS x64 (Windows 10 and newer) as well as for Linux OS (few distros, to get the demo application for a specific Linux distro send us a request). Table 9 shows the list of files of the demo application.
Table 9 - List of files of demo application (example for Windows OS).
| File | Description |
|---|---|
| DnnOnnxDetectorDemo.exe | Demo application executable file for windows OS. |
| DnnOnnxDetectorDemo.json | Demo application config file. |
| onnxruntime.dll | ONNX Runtime library file for Windows x64. |
| onnxruntime_providers_shared.dll | ONNX Runtime library file for Windows x64. |
| onnxruntime_providers_openvino_plugin.dll and the other files of the folder native | Only for OpenVINO (type 1, 2 and 3): the plugin library and the OpenVINO libraries. They must be in the folder of the executable file, see GETTING_STARTED.md, step 10. |
| test.mp4 | Test video file. |
| thermal.onnx | Example of YOLOv8 neural network. |
To launch demo application run DnnOnnxDetectorDemo.exe executable file on Windows x64 OS or run commands on Linux:
sudo chmod +x DnnOnnxDetectorDemo
./DnnOnnxDetectorDemo
To build the demo application from the source code and run it, see GETTING_STARTED.md. If a message about missing system libraries appears (on Windows OS) when launching the application, you must install the VC_redist.x64.exe program, which will install the system libraries required for operation. Config file DnnOnnxDetectorDemo.json includes video capture params (videoSource section) and object detector parameters (objectDetector section). If the demo application does not find the file after startup, it will create it with default parameters. Config file content:
{
    "Params": {
        "objectDetector": {
            "classNames": [
                "bus",
                "car",
                "person"
            ],
            "custom1": -1.0,
            "custom2": -1.0,
            "custom3": -1.0,
            "enable": true,
            "frameBufferSize": -1,
            "initString": "thermal.onnx;640;640",
            "logMode": 0,
            "maxObjectHeight": 256,
            "maxObjectWidth": 256,
            "maxXSpeed": -1.0,
            "maxYSpeed": -1.0,
            "minDetectionProbability": 0.5,
            "minObjectHeight": 4,
            "minObjectWidth": 4,
            "minXSpeed": -1.0,
            "minYSpeed": -1.0,
            "numThreads": -1,
            "resetCriteria": 10,
            "scaleFactor": -1,
            "sensitivity": -1.0,
            "type": 0,
            "xDetectionCriteria": 1,
            "yDetectionCriteria": 1
        },
        "videoSource": "test.mp4"
    }
}
Table 10 - Parameters description.
| Field | Type | Description |
|---|---|---|
| videoSource | Video source initialization string. Default value “test.mp4” (the file must be in the working directory of the application). If the parameter is set to “file dialog”, then after start the program will offer to select video file via file selection dialog. The parameter must contain a video file name or a full path (e.g. “test.mp4”). The demo application was tested with .mp4 files, for the other supported formats see the documentation of the VSourceFile library. When capturing video from a video file, the software plays the video with repetition i.e. when the end of the video file is reached, playback starts again. | |
| classNames | string | A list of object class names used in detectors that recognize different object classes. Detected objects have an attribute called ‘type.’ If a detector doesn’t support object class recognition or can’t determine the object type, the ‘type’ field must be set to 0. Otherwise, the ‘type’ should correspond to the ordinal number of the class name from the ‘classNames’ list (if the list was set in params), starting from 1 (where the first element in the list has ‘type == 1’). In the provided example, classNames are created based on YOLO models layout. DnnOnnxDetector sets the field type of an object to the zero-based index of the class: the class with the index 0 has type 0. |
| custom1 | float | Not used. Can have any value. |
| custom2 | float | Not used. Can have any value. |
| custom3 | float | Not used. Can have any value. |
| enable | bool | Enable / disable detector. |
| frameBufferSize | int | Not used. Can have any value. |
| initString | string | In initString, path to neural network model in ONNX format that has standard one-batch layout have to be included. Also there should be included dimensions (width;height) of neural network input images, everything separated by semicolon. E.g.: “./model.onnx;640;640”. The format “model;weights;width;height” is also accepted, but the weights item is not used: ONNX Runtime reads the weights from the model file. |
| logMode | int | Not used. Can have any value. |
| maxObjectHeight | int | Maximum object height to be detected, pixels of the video frame. To be detected object’s height must be <= maxObjectHeight. Default value 256. |
| maxObjectWidth | int | Maximum object width to be detected, pixels of the video frame. To be detected object’s width must be <= maxObjectWidth. Default value 256. |
| maxXSpeed | float | Not used. Can have any value. |
| maxYSpeed | float | Not used. Can have any value. |
| minDetectionProbability | float | Defines threshold for object detection probability. Only objects with probability greater than minDetectionProbability will be detected. Can have any values from 0 to 1, but the detector discards the results with a probability below 0.3 before the threshold is applied, so a value below 0.3 gives the same result as 0.3. |
| minObjectHeight | int | Minimum object height to be detected, pixels of the video frame. To be detected object’s height must be >= minObjectHeight. Default value 4. |
| minObjectWidth | int | Minimum object width to be detected, pixels of the video frame. To be detected object’s width must be >= minObjectWidth. Default value 4. |
| minXSpeed | float | Not used. Can have any value. |
| minYSpeed | float | Not used. Can have any value. |
| numThreads | int | Not used. Can have any value. |
| resetCriteria | int | The number of consecutive video frames in which the object was not detected, so it will be excluded from the internal object list. The internal object list is used to associate newly detected objects with objects detected in the previous video frame. Internal objects list allows the library to keep static object ID from frame to frame. If the object is not detected during a number of frames < resetCriteria, the next detection will not change the object ID. Valid values from 1 to 8192. |
| scaleFactor | int | Not used. Can have any value. |
| sensitivity | float | Not used. Can have any value. |
| type | int | Type defines the execution provider of ONNX Runtime for neural network model computation. 0 - CPU, 1 - OpenVINO CPU, 2 - OpenVINO on the first GPU, 3 - OpenVINO on the first discrete GPU. Values 1, 2 and 3 need the OpenVINO plugin library, see section OpenVINO execution provider. Another value makes initialization fail. Default value 0. |
| xDetectionCriteria | int | The same meaning as yDetectionCriteria. The number of video frames on which the object was detected so that it will be included in the list of detected objects. The library has detection counter for each object. After each detection the library increases detection counter for particular object. When detection counter >= xDetectionCriteria, this object will be included into output detected objects list. If object not detected the library decreases detection counter. When user calls setParam(…) for xDetectionCriteria, the yDetectionCriteria will be set automatically to the same value. Also method getParams(…) will return same value for xDetectionCriteria and yDetectionCriteria. Valid values from 1 to 8192. |
| yDetectionCriteria | int | The same meaning as xDetectionCriteria. The number of video frames on which the object was detected so that it will be included in the list of detected objects. The library has detection counter for each object. After each detection the library increases detection counter for particular object. When detection counter >= yDetectionCriteria, this object will be included into output detected objects list. If object not detected the library decreases detection counter. When user calls setParam(…) for yDetectionCriteria, the xDetectionCriteria will be set automatically to the same value. Also method getParams(…) will return same value for xDetectionCriteria and yDetectionCriteria. Valid values from 1 to 8192. |
After starting the application (running the executable file) the application plays the video file test.mp4 from the working directory (if parameter “videoSource” in config file is set to “file dialog”, the user should select the video file in the dialog box). The user will see the user interface as shown below. The window shows the video with detection results and the sliders of the detection parameters. Each detected object is represented by a red rectangle and metadata above which includes (left to right): detection probability, object ID and class name.
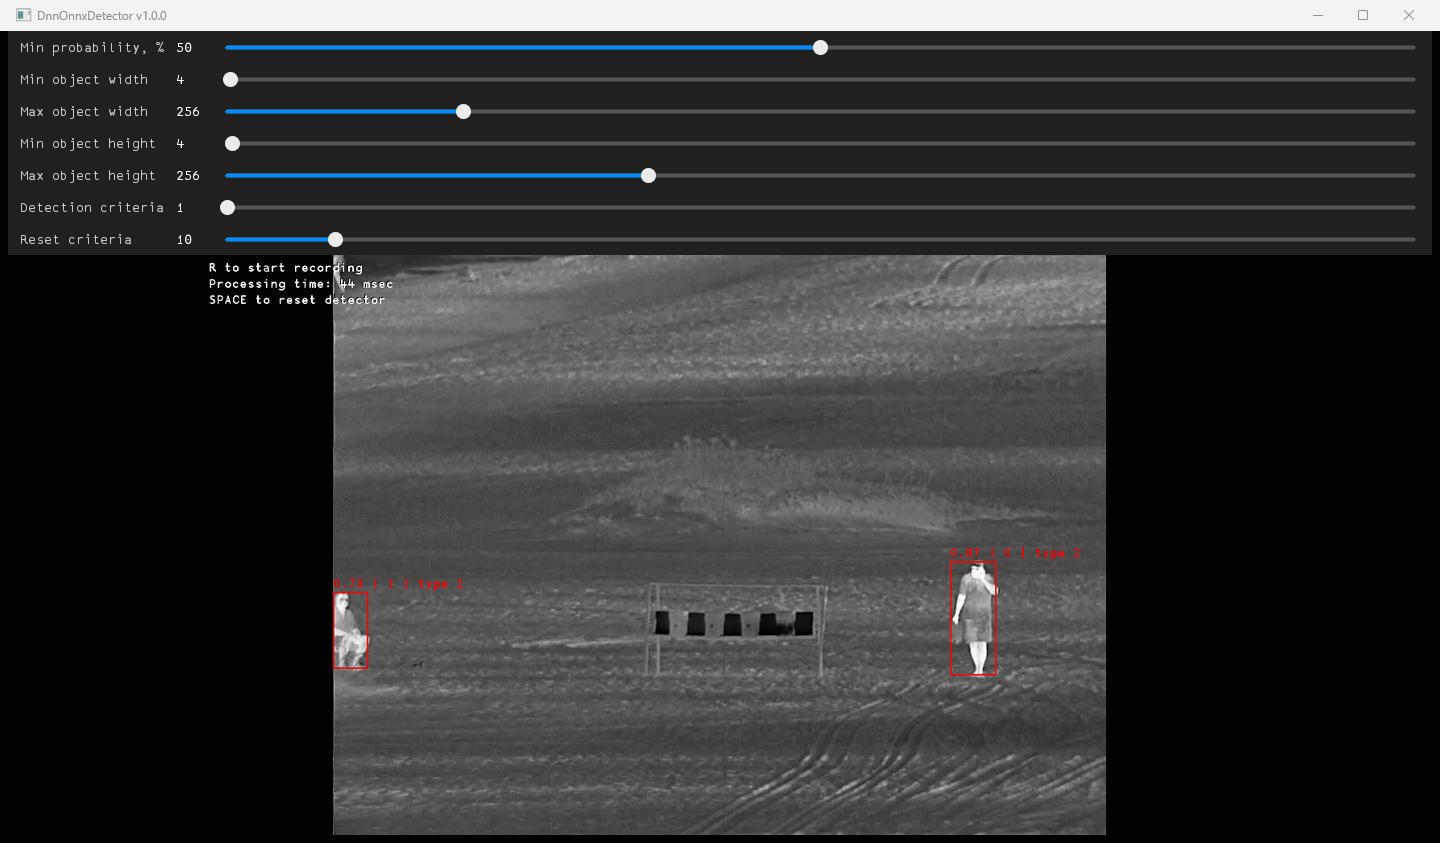
Control
To control the application, the main video display window must be active (in focus), and the English keyboard layout must be activated without CapsLock mode. The program is controlled by the keyboard and mouse (detection ROI control).
Table 11 - Control buttons.
| Button | Description |
|---|---|
| ESC | Exit the application. If video recording is active, it will be stopped. |
| SPACE | Reset object detector. |
| R | Start/stop video recording. When video recording is enabled, a file dst_[date and time].mp4 (result video) is created in the current folder (the folder from which the application is started). Recording is performed of what is displayed to the user. To stop the recording, press the R key again. During video recording, the application shows a warning message. |
The minimum detection probability, the minimum and maximum object width and height, the detection criteria and the reset criteria are changed with the sliders in the window. The user can set the detection mask (mark a rectangular area where objects are to be detected). In order to set a rectangular detection area it is necessary to draw a line with the mouse with the left button pressed from the left-top corner of the required detection area to the right-bottom corner. The detection area will be marked in blue color as shown in the image.